Best Seller Icon Bestseller

Excellence In ROBO CAR(S-ERC-5845)

  • Last updated Oct, 2026
  • Certified Course

Course Includes

  • Duration2 Months
  • Enrolled0
  • Lectures50
  • Videos0
  • Notes0
  • CertificateYes

What you'll learn

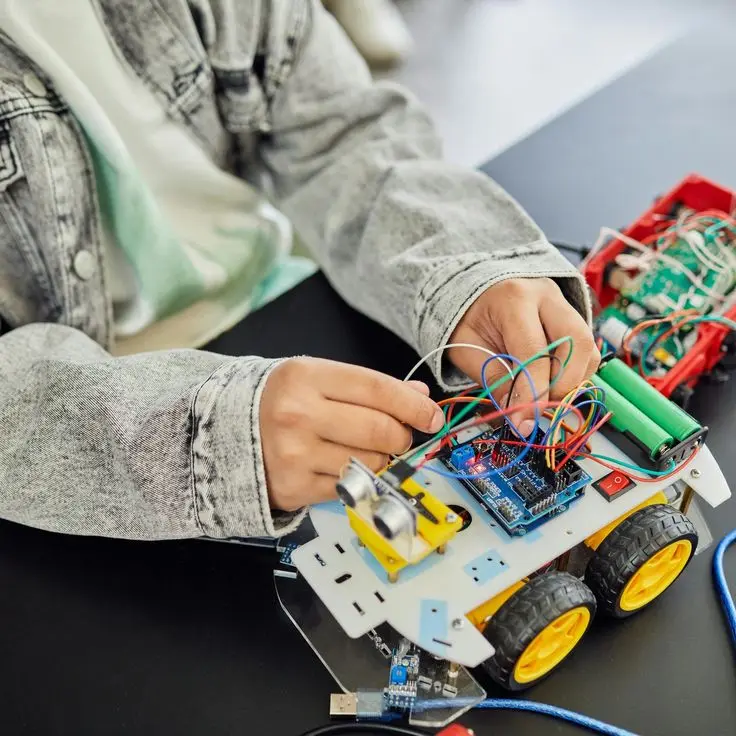
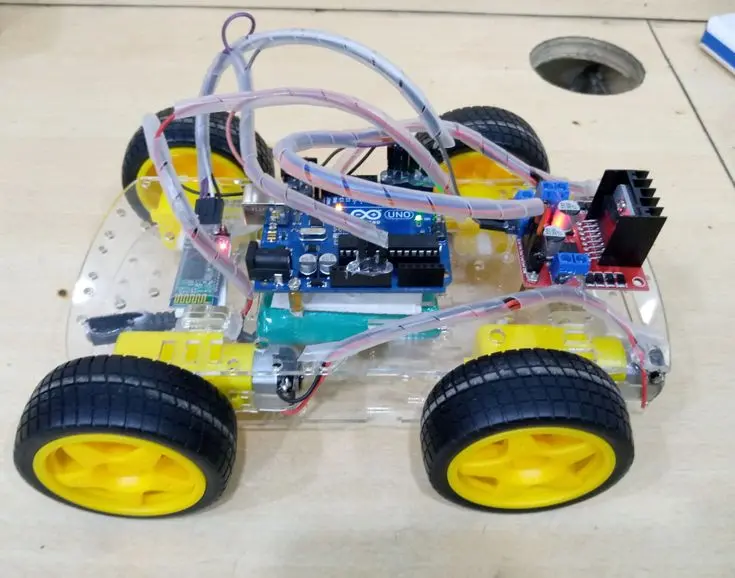
The Robo Car course is a practical robotics program designed to teach learners how to build, program, and operate a robotic vehicle. The course combines electronics, Arduino programming, DC motors, motor drivers, sensors, chassis assembly, remote control, obstacle avoidance, and line-following technologies.

Students learn how a robotic car receives inputs from sensors or remote-control systems and uses programmed instructions to control its motors and movement. The course provides hands-on experience in assembling circuits, programming microcontrollers, integrating sensors, testing robotic movement, and developing functional Robo Car projects.

What You Will Learn

  • Fundamentals of robotics and robotic vehicles
  • Electronics and basic circuit connections
  • Arduino microcontroller programming
  • DC geared motor control
  • Motor driver operation
  • Robo Car chassis and mechanical assembly
  • Forward, reverse, left and right movement
  • IR and Bluetooth remote control concepts
  • Ultrasonic and IR sensor integration
  • Obstacle detection and avoidance
  • Line-following robot development
  • Speed control using PWM
  • Battery and power management
  • Hardware and software troubleshooting
  • Development of complete Robo Car projects

Who Can Join?

  • School students
  • Robotics beginners
  • STEM learners
  • Engineering and diploma students
  • ITI and technical students
  • Electronics students
  • Arduino beginners
  • Robotics enthusiasts
  • Students interested in automation and embedded systems

Prerequisite

Basic computer knowledge and logical thinking are helpful. Basic electronics knowledge is an advantage but not mandatory. No previous robotics experience is required.

Course Outcome

After completing this course, learners will be able to:

  • Understand the basic architecture of robotic vehicles.
  • Identify and connect major Robo Car components.
  • Build an Arduino-based robotic car.
  • Control DC motors using a motor driver.
  • Program different robot movements.
  • Integrate IR, ultrasonic and other basic sensors.
  • Develop obstacle detection and avoidance functions.
  • Create basic line-following robot applications.
  • Implement remote-control features.
  • Troubleshoot common hardware, wiring and programming problems.
  • Design and demonstrate a complete Robo Car project.

Career & Learning Opportunities

  • Robotics Project Assistant
  • Robotics Technician – Entry Level
  • Arduino Project Trainee
  • Embedded Systems Trainee
  • Electronics Project Trainee
  • Automation Trainee
  • Robotics Programming Assistant
  • Robotics Lab Assistant
  • STEM Project Assistant
  • IoT & Robotics Project Assistant
  • STEM/Robotics Trainer – Entry Level


Show More

Course Syllabus

Module 1: Introduction to Robo Car

  • Introduction to robotics
  • What is a Robo Car?
  • Working principle of robotic vehicles
  • Applications of Robo Cars
  • Types of robotic cars
  • Basic components required
  • Introduction to autonomous and remote-controlled cars

Module 2: Electronics Fundamentals

  • Basic electronic components
  • Voltage, current and resistance
  • Resistors and capacitors
  • LEDs and switches
  • Breadboard fundamentals
  • Basic circuit connections
  • Power supply concepts

Module 3: Robo Car Components

  • Microcontroller
  • DC geared motors
  • Wheels and chassis
  • Motor driver
  • Battery and power supply
  • Sensors
  • Connecting wires and electronic modules

Module 4: Microcontroller Fundamentals

  • Introduction to microcontrollers
  • Arduino overview
  • Arduino board components
  • Digital and analog pins
  • Input and output devices
  • Connecting components to Arduino
  • Basic microcontroller applications

Module 5: Arduino Programming Basics

  • Introduction to Arduino IDE
  • Program structure
  • Variables and data types
  • Operators
  • Conditional statements
  • Loops
  • Functions
  • Uploading and testing programs

Module 6: DC Motors & Motor Control

  • Working of DC geared motors
  • Motor specifications
  • Forward and reverse rotation
  • Left and right movement
  • Motor speed control
  • PWM fundamentals
  • Motor testing and troubleshooting

Module 7: Motor Driver Module

  • Need for a motor driver
  • Introduction to L298N/L293D
  • Motor driver connections
  • Controlling multiple motors
  • Direction control
  • Speed control
  • Motor driver troubleshooting

Module 8: Robo Car Chassis & Assembly

  • Chassis design
  • Wheel installation
  • Motor mounting
  • Battery placement
  • Circuit component placement
  • Wiring arrangement
  • Mechanical alignment
  • Complete Robo Car assembly

Module 9: Basic Robo Car Movement

  • Forward movement
  • Reverse movement
  • Left turn
  • Right turn
  • Stop function
  • Movement combinations
  • Testing movement commands
  • Programming movement sequences

Module 10: Remote Control Robo Car

  • Introduction to remote control
  • IR remote control concepts
  • Bluetooth control concepts
  • Wireless command transmission
  • Mobile-based control
  • Remote movement programming
  • Testing remote-control functions

Module 11: Sensor Integration

  • Introduction to robotic sensors
  • Ultrasonic sensor
  • IR sensor
  • Line sensor concepts
  • Distance measurement
  • Sensor connections
  • Reading sensor values
  • Sensor-based robot control

Module 12: Obstacle Detection & Avoidance

  • Introduction to obstacle detection
  • Ultrasonic distance measurement
  • Setting detection thresholds
  • Obstacle detection programming
  • Automatic stopping
  • Direction selection
  • Obstacle avoidance logic
  • Testing an obstacle-avoiding Robo Car

Module 13: Line Following Robo Car

  • Introduction to line-following robots
  • IR sensor array
  • Black and white surface detection
  • Sensor calibration
  • Line detection programming
  • Motor control based on sensor input
  • Turning and correction logic
  • Line-following testing

Module 14: Advanced Robo Car Features

  • Multiple operating modes
  • Automatic and manual control
  • Variable speed control
  • Sensor-assisted movement
  • Emergency stop function
  • LED and buzzer indicators
  • Advanced movement logic

Module 15: Power Supply & Battery Management

  • Battery types
  • Selecting suitable batteries
  • Voltage requirements
  • Power distribution
  • Battery connections
  • Safe battery handling
  • Power consumption
  • Improving battery efficiency

Module 16: Programming & Troubleshooting

  • Arduino program debugging
  • Motor troubleshooting
  • Sensor troubleshooting
  • Wiring problems
  • Power supply issues
  • Communication problems
  • Calibration problems
  • Hardware and software testing

Module 17: Robo Car Applications

  • Educational robotics
  • Autonomous robotic vehicles
  • Remote inspection robots
  • Obstacle avoidance applications
  • Line-following applications
  • Smart transportation concepts
  • Industrial mobile robot concepts
  • STEM robotics applications

Module 18: Robo Car Project Design

  • Project planning
  • Component selection
  • Circuit design
  • Chassis design
  • Sensor placement
  • Programming workflow
  • Testing and improvement
  • Project documentation

Module 19: Practical Robo Car Projects

  • Basic Arduino Robo Car
  • Remote-controlled Robo Car
  • Bluetooth-controlled Robo Car
  • Obstacle-avoiding Robo Car
  • Line-following Robo Car
  • Sensor-based Robo Car
  • Multi-mode robotic vehicle

Module 20: Final Robo Car Project

  • Complete Robo Car assembly
  • Circuit integration
  • Motor and sensor connections
  • Arduino programming
  • Manual and automatic control
  • Movement and sensor testing
  • Troubleshooting
  • Final project demonstration
  • Practical assessment


Review

0.0
Course Rating (0 reviews)
0%
0%
0%
0%
0%


Call
Text Message
Review
Email
CHAT